We met briefly on Monday and discussed whether or not to participate in Robo Rodeo. We all mostly agreed that it wouldn’t benefit our team to participate. We haven’t had enough practice and don’t have enough time to get enough practice to make for a good showing. So instead, we’re planning a simple pick and place game for the fall.
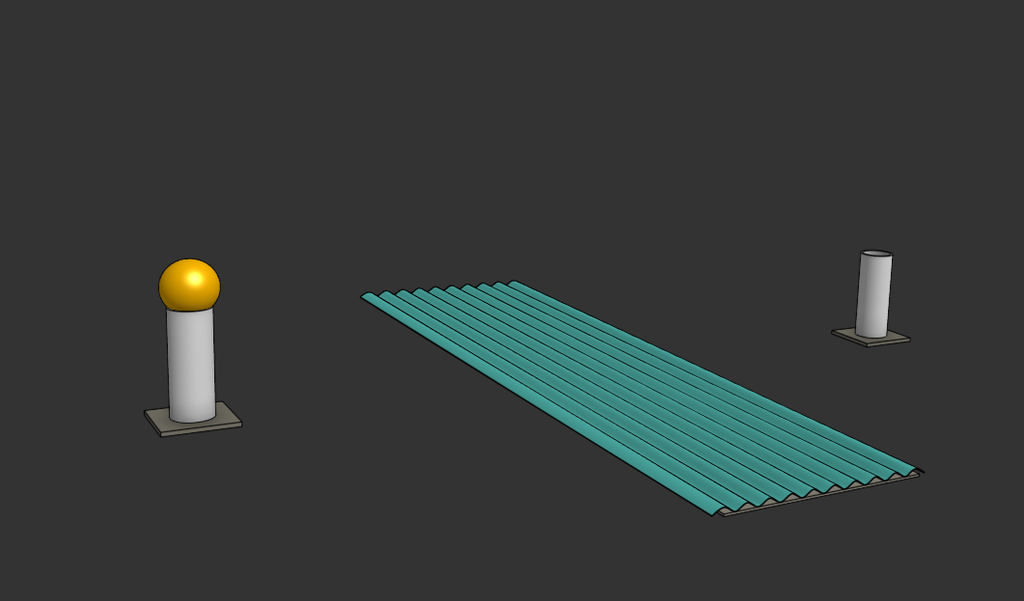
We’ll set up two Pedestals made from PVC pipe about 25 feet apart with a surface in between those two pedestals made up of a piece of corrugated PVC roofing material. On top of one of the pedestals we will place last year’s game piece, the yellow ball. The objective is simple: From a starting line, a robot must drive to the first pedestal and pick up the ball, drive over the rough terrain, and place the ball on the other pedestal. That’s it.
We can begin making prototypes for object manipulation at our next meeting and make decisions about an appropriate drivetrain and work towards a fully functional autonomous routine to do just that. Hopefully by November, we’ll have made this game more complicated because we’re too good at it for it to be a real challenge. We shall see.